
| Product Condition | New original or used original. Please confirm the condition with us before ordering. |
| Shipping Information | Worldwide shipping via DHL, FedEx, and UPS. 3-5 working days to most destinations. Packed with protective film and a reinforced carton. |
| Buyer Benefits |
|
| Item Location | Ships from Shanghai, China. Lead time confirmed with your inquiry. |
| Payment Information | PayPal, T/T, and Alibaba Trade Assurance accepted. Send your inquiry for a quotation. |

12,000+ parts in stock,Tested before shipping,Reply within 24 hours
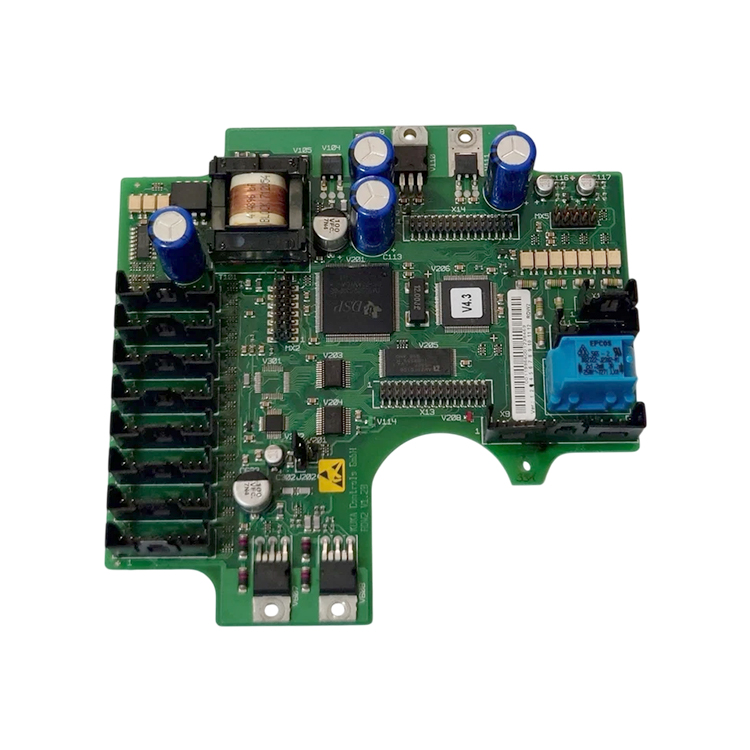
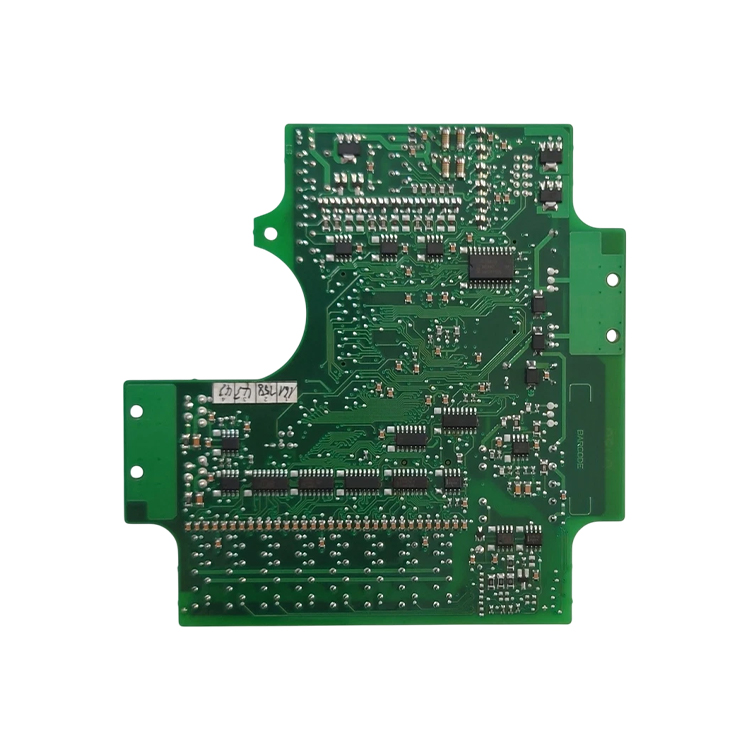
InquiryThe KUKA 00-119-966 is the resolver digital converter of the earlier RDW controller generation, listed in the KUKA catalogue as RDC 2 Resolver Digital Converter 120MHz and also traded as the RDW2 board. KUKA describes it as a converter with a digital signal processor that converts analog signals to digital signals and that is mounted in an RDC box on the base frame of the robot. That is the position feedback link of the machine: the resolvers on the axis motors deliver analog sine and cosine signals, this board turns them into digital position data, and the controller uses that data for every axis. The unit weighs 0.176 kg and carries customs HS code 85389091. Because a fault here does not stop the drive and does not stop the motor, it shows up as a position problem, a mastering problem or a communication message between the controller and the robot base. Send us the article number on the board or the robot serial number, and we confirm the match before you order.
| Manufacturer | KUKA (original spare part) |
| Part Number | 00-119-966 |
| Catalogue name | RDC 2 Resolver Digital Converter 120MHz |
| Type | Resolver digital converter board (RDC 2), also sold as the RDW2 board |
| Function | Converts the analog resolver signals of the robot axes into digital position data and sends them to the controller |
| Signal processing | Digital Signal Processor, 120 MHz |
| Mounting position | RDC box on the base frame of the robot |
| Net weight | 0.176 kg |
| Customs HS code | 85389091 |
| Condition | New original or used original. Please confirm the condition with us before ordering. |
| Details confirmed before supply | The module version and the robot it came from are confirmed against the unit in your cabinet before we ship. Send us the article number on the board or the robot serial number. |
Send the article number printed on the board, the robot serial number or a photo of the label, and we confirm the match before you order.
The drive side of a robot axis is driven, but the position of the axis is measured, and on this generation the measuring element is a resolver in the motor. A resolver outputs two analog signals whose amplitude and phase carry the angle of the shaft, and the controller cannot work with an analog signal, so something has to sit between the motor and the controller and convert. That is the job of the resolver digital converter, and the 00-119-966 is the KUKA unit that does it on the RDW generation. The catalogue name says what it is: RDC 2, the second generation of the resolver digital converter, with a digital signal processor running at 120 MHz. KUKA states that the unit is mounted in an RDC box on the base frame of the robot, which is the point of the design: the board sits in the machine, close to the resolvers, and the position data travels to the cabinet over the data cable rather than the drive cables carrying power. The RDC box is the housing that takes the board and gives it its connection to the robot, and the board inside it is the replaceable element. The controller side of this link is the DSE, the drive computer in the cabinet, and the KUKA operating instructions for the KR C2 ed05 treat the pair as one diagnostic unit: the DSE-RDW diagnostic tool is opened under Setup, Service, DSE-RDW, and inside it the module is addressed as 1.RDC2, with a Table, an Offset and symmetry function and a Check communication function. The Check communication function states that the RDC sends data words to the DSE in a 125 microsecond cycle, which is the heartbeat of the whole position chain and the reason a single failed transmission is visible to the controller. One further property of the design matters for a replacement: the contents of the EEPROM in the RDC unit can be overwritten and cannot be restored simply by booting the system, so the module carries data of its own that has to be written again after the exchange. That is why a converter is identified by its article number and by the robot it came from, and that is what we confirm before a replacement is shipped.
The KUKA KR C2 ed05 operating instructions define what has to be done after the exchange, and this is the part that a buyer should plan for. The Offset and symmetry function carries a Set default values softkey, and the manual states that the default values should be set after exchanging motors, after exchanging the RDC module and after sporadic encoder errors. The RDC table also shows the measurement and configuration data of the module, with an Export softkey, so the state of the old module can be read before it is removed. The manual further states that the contents of the EEPROM in the RDC unit can be overwritten and cannot be restored simply by booting the system, so the robot number has to be set on the new module again, and the axes have to be mastered afterwards. Please contact us with the fault code shown on your controller for an accurate diagnosis of your cabinet. The practical point for a buyer is that the board is the cheap part of this repair and the procedure is the expensive part of it, and a service team that plans the three steps of setting the default values, writing the robot number and mastering the axes in advance will get the machine back into production in one visit.
Request a quote: send your part number (00-119-966) or the robot serial number, and we confirm the module version, the fit and the lead time before you order.
If you have any suggestions, please contact us
Contact Us
