
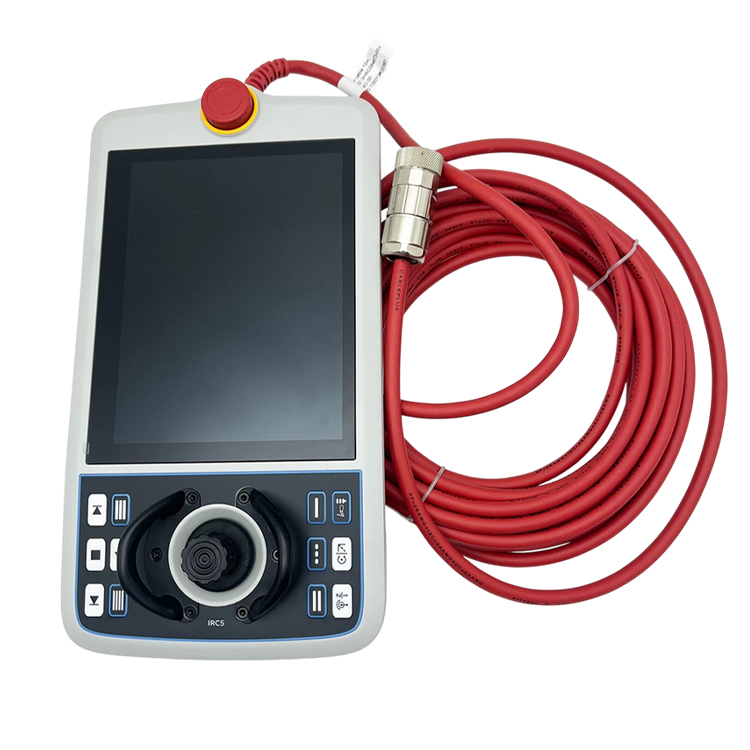
| Product Condition | New original or used original. Please confirm the condition with us before ordering. |
| Shipping Information | Ships from Shanghai, China. Typical handling and transit: 3–5 working days via DHL, FedEx or UPS, with secure protective packaging for sensitive electronics. |
| Buyer Benefits |
|
| Item Location | Ships from Shanghai, China. |
| Payment Information | We accept PayPal, T/T (bank transfer) and Alibaba Trade Assurance. |

12,000+ parts in stock,Tested before shipping,Reply within 24 hours
Inquiry| Product Category | ABB Robot Spare Parts — Teach Pendant / FlexPendant (operator interface) |
| Brand | ABB |
| Product Name | FlexPendant (robot operator pendant) |
| Part Number | 3HAC085590-001 |
| Type Designation | DSQC3120A |
| Interface Designation | SxTPU4 (TPU4) |
| Supplied With | Connection cable (per ABB product identity) |
| Function | Local robot programming, manual jogging, operating-mode interaction and diagnostics at the controller. |
| Operator Controls | Keypad and joystick interface. |
| Safety Devices | Integrated emergency-stop and enabling (deadman) device. |
| Display | 7-inch color TFT touchscreen, 800 × 480 resolution. |
| Power Supply | 24 V DC, supplied from the robot controller. |
| Ingress Protection | IP65 (dust-tight, protected against water jets and oil). |
| Net Weight | Approx. 1.2 kg. |
| Part Type | New |
| Detailed Technical Parameters | ABB does not publish full electrical specifications openly. Confirm the exact controller generation, RobotWare / RobotControl software version and cable configuration from your unit's nameplate and service documentation before ordering. |
This is the handheld human interface that sits between the operator and the robot controller — not a generic touch panel. Robot work at the cell needs a device that is always local, rugged and safety-rated: the operator holds it while standing next to the robot, so it must survive drops, oil, dust and daily abuse while remaining safe to use. That is why it is a purpose-built pendant on a controller-connected cable rather than a laptop or tablet.
The safety architecture is the core of the design. A three-position enabling (deadman) switch and a hardwired emergency stop mean the robot can only move while the operator is actively and consciously holding the pendant in the safe state — release it and motion stops. Programming, jogging and diagnostics then all flow through one controller-connected device, keeping the cell operable even when the network or office PC is not. Because the pendant is tied to a controller generation and its software, selection must match the installed system rather than just the enclosure appearance.
If you have any suggestions, please contact us
Contact Us
