
| Product Condition | New original or used original. Please confirm the condition with us before ordering. |
| Shipping | Ships from Shanghai, China. Delivery lead time: 3-5 working days after order confirmation. Worldwide delivery by DHL / FedEx / UPS with secure packaging. |
| Buyer Benefits |
|
| Item Location | Ships from Shanghai, China. |
| Payment | PayPal / T/T / Alibaba Trade Assurance. |

12,000+ parts in stock,Tested before shipping,Reply within 24 hours
Inquiry| Category | ABB Robot Manipulator Harness Assembly / Cable Unit |
| Brand | ABB |
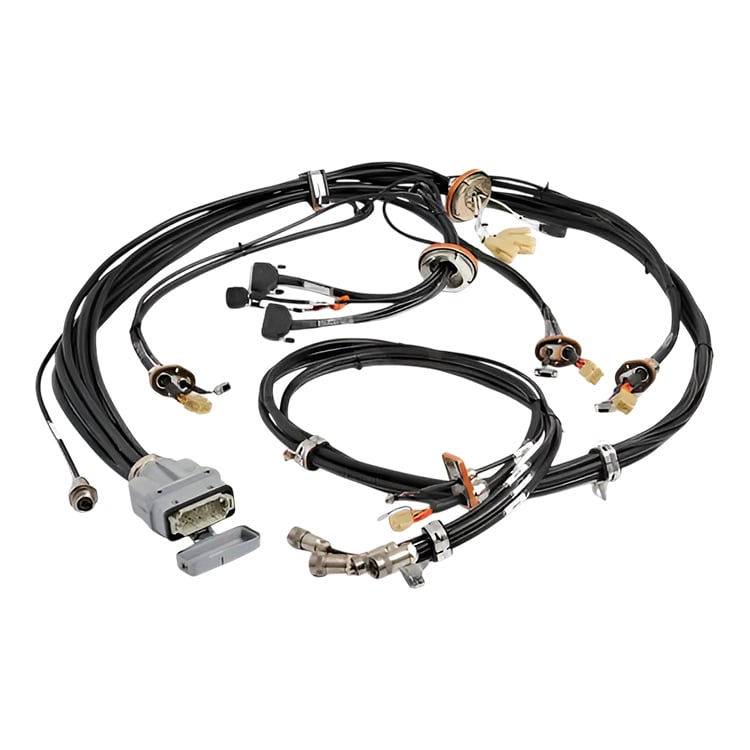
| Product Name | Manipulator Harness Assembly (Robot Cable Unit) |
| Part Number | 3HAC8009-1 |
| Function | Carries power and signal wiring through the robot manipulator as a defined cable assembly, organizing internal cable routing and reducing mechanical stress during motion. |
| Definition | ABB 3HAC8009-1 is a manipulator harness assembly (robot cable unit) for ABB robots, used to route power and signal lines inside the manipulator. |
| Series / Compatibility | Exact robot model and harness revision are not published in the ABB catalog for this article number. Confirm your robot model and harness revision from the spare-parts list or maintenance manual before ordering — this assembly is revision-specific. |
| Net Weight | 8.94 kg (ABB spare-parts catalog) |
| Customs Tariff Number | 85444290 |
| Part Type | New / original — condition confirmed with you before ordering. |
| Detailed Technical Parameters | Robot model, physical dimensions and electrical rating are not published for this article number. Confirm the exact robot model, harness revision and connector map from the spare-parts list / maintenance manual before ordering. Weight and tariff per ABB spare-parts catalog. |
A robot manipulator contains many power and signal lines that must flex thousands of times across every axis. Running each conductor loose would create a stiff, failure-prone loom. ABB groups these lines into one defined harness assembly so the cabling moves as a managed bundle — protecting conductors from abrasion and keeping the manipulator's internal routing organized rather than a nest of loose cables.
Because the assembly is a defined spare tied to a specific robot model and harness revision, it is not a universal fit. The correct article number depends on the exact robot and the documented revision, so the part must be matched against the spare-parts list or maintenance manual rather than chosen by appearance. This is a confirmed-fitment spare, verified by robot model and revision, not a generic cable.
If you have any suggestions, please contact us
Contact Us
