
| Product Condition | New original or used original. Please confirm the condition with us before ordering. |
| Shipping Information | Worldwide shipping via DHL, FedEx, and UPS. 3-5 working days to most destinations. Packed with protective film and a reinforced carton. |
| Buyer Benefits |
|
| Item Location | Ships from Shanghai, China. Lead time confirmed with your inquiry. |
| Payment Information | PayPal, T/T, and Alibaba Trade Assurance accepted. Send your inquiry for a quotation. |

12,000+ parts in stock,Tested before shipping,Reply within 24 hours
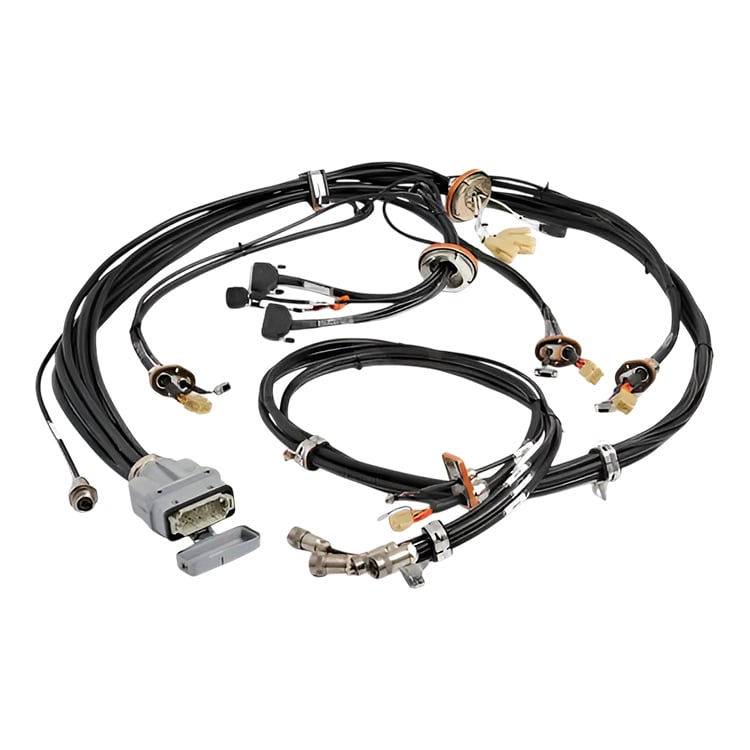
InquiryThe ABB 3HAC8009-1 is the manipulator harness assembly for ABB IRB 6400R robots. ABB lists it in its spare part catalogue as "Harness assembly manip." — the complete harness that runs the internal power and signal wiring through the manipulator, from the base to the upper arm and wrist. It arrives as one defined assembly with the factory connectors already fitted, so it replaces the harness as a complete unit rather than as a loose set of individual cables. Send us the robot serial number and the article number on the harness label, and we confirm the match before you order.
| Part number | 3HAC8009-1 |
| Manufacturer | ABB (original spare part) |
| ABB catalogue name | Harness assembly manip. |
| Type | Manipulator harness assembly (robot cable unit) — the internal power and signal wiring of the manipulator, supplied as one complete assembly |
| Compatibility | ABB IRB 6400R robots. Send us your robot serial number and the article number on the harness label, and we confirm the match before you order. |
| Net weight | 8.94 kg |
| Gross weight | 9.3 kg |
| ABB type designation | 55x37x18 |
| Customs HS code | 85444290 |
| Minimum order quantity | 1 piece |
| Country of origin | Czech Republic (CZ) |
| Condition | New original or used original. Please confirm the condition with us before ordering. |
Send the robot serial number and the article number printed on the harness label, and we confirm the match before you order.
A robot manipulator contains many power and signal lines that must flex thousands of times across every axis. Running each conductor loose would create a stiff, failure-prone loom. ABB groups these lines into one defined harness assembly so the cabling moves as a managed bundle — protecting conductors from abrasion and keeping the manipulator's internal routing organised rather than a nest of loose cables. On the IRB 6400R this harness runs through the base, the lower arm and the upper arm, where it has to follow the arm through every permitted motion while carrying servo power, measurement signals and the customer-side signals that the cell needs at the tool flange.
The assembly is a defined spare tied to one robot type, so it is not a universal fit. Rather than comparing it by appearance, the reliable route is the label on the harness you are replacing and the serial number of the robot it came from — send us both and we match them against the ABB spare part data before you order.
Before removal: isolate and lock out the robot power, and confirm the article number on the harness against the robot serial number. Photograph and label every connector and its routing before you take the harness out, keep the new harness clear of moving structures and heat sources, and check that the connectors lock. After fitting, run the robot in manual at reduced speed and confirm the axes move cleanly with no connector strain before the cell returns to production.
Request a quote: Send your robot serial number and the article number on the harness label (3HAC8009-1). We confirm condition, fitment and lead time, then send a quotation — before you place any order.
If you have any suggestions, please contact us
Contact Us
